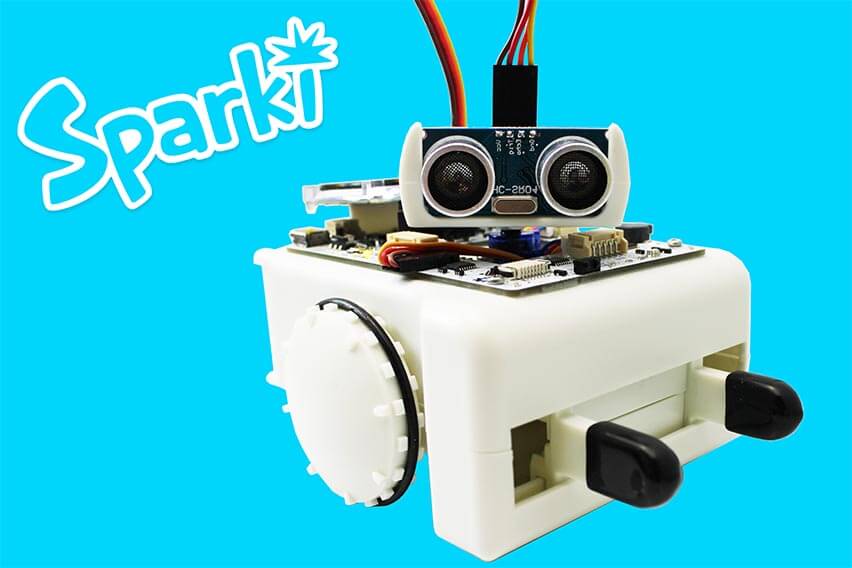
Parts of Sparki
A library reference for all parts of Sparki
Here's all the parts that make up Sparki! Click on a part for more information on how it works and how to use it. Each part also has a quick reminder reference below it for the commands that go along with it. Accelerometer
sparki.accelX();
sparki.accelY();
sparki.accelZ();
Bluetooth Module
Serial1.read();
Serial1.print();
Serial1.println();
Buzzer
sparki.beep();
sparki.beep(int freq);
sparki.beep(int freq, int time);
Expansion Port Gripper
sparki.gripperOpen();
sparki.gripperOpen(width_cm);
sparki.gripperClose();
sparki.gripperClose(width_cm);
sparki.gripperStop();
Infrared LED
sparki.sendIR();Infrared Reflectance Sensor
sparki.edgeLeft();
sparki.lineLeft();
sparki.lineCenter();
sparki.lineRight();
sparki.edgeRight();
Infrared Remote Infrared Remote Receiver
sparki.readIR();LCD
sparki.clearLCD();
sparki.updateLCD();

sparki.drawPixel(xPixel, yPixel);
sparki.readPixel(xPixel, yPixe);
sparki.drawChar(xPixel, yLine, char);
sparki.drawString(xPixel, yLine, *char);
sparki.drawLine(xStart, yStart, xEnd, yEnd);
sparki.drawRect(xCenter, yCenter, width, heigh);
sparki.drawRectFilled(xCenter, yCenter, width, height);
sparki.drawCircle(xCenter, yCenter, radius);
sparki.drawCircleFilled(xCenter, yCenter, radius);
sparki.drawBitmap(xStart, yStart, *bitmap, width, height);
Light Sensor
sparki.lightLeft();
sparki.lightCenter();
sparki.lightRight();
Magnetometer
sparki.magX();
sparki.magY();
sparki.magZ();
Marker Holder On/Off Switch Radio
radio.writeChar(char)
radio.writeInt(int)
radio.writeFloat(float)

radio.readChar()
radio.readInt()
radio.readFloat()

radio.available()
Reset Button RGB LED
sparki.RGB(R,G,B);Status LED
digitalWrite(STATUS_LED, HIGH);
digitalWrite(STATUS_LED, LOW);
analogWrite(STATUS_LED, 0);
analogWrite(STATUS_LED, 123);
analogWrite(STATUS_LED, 255);
Wheels
sparki.moveForward(distance_centimeters);
sparki.moveBackward(distance_centimeters);
sparki.moveLeft(angle_degrees);
sparki.moveRight(angle_degrees);
sparki.moveStop();
Servo
sparki.servo(angle_degrees);Stepper Motors
sparki.motorRotate(int motor, int direction,  int speed);
sparki.motorStop(int motor);
Ultrasonic Range Finder
sparki.ping();


